Metakon LLP –
Robotic Assembly & Welding
A dedicated dual-robot cell for repeated foundation supports, programmed using touch-up. This is a separate serial-production application, not a STEELFAB model or a Tekla-generated job workflow.
The Challenge
The application concerns repeated foundation support products prepared for a dedicated robotic cell. Separate manual fit-up and welding steps made production flow dependent on operator availability and coordination.
The robot program is prepared through touch-up of taught points. The project illustrates serial-production automation, rather than automatic task generation from a Tekla model.
The Solution
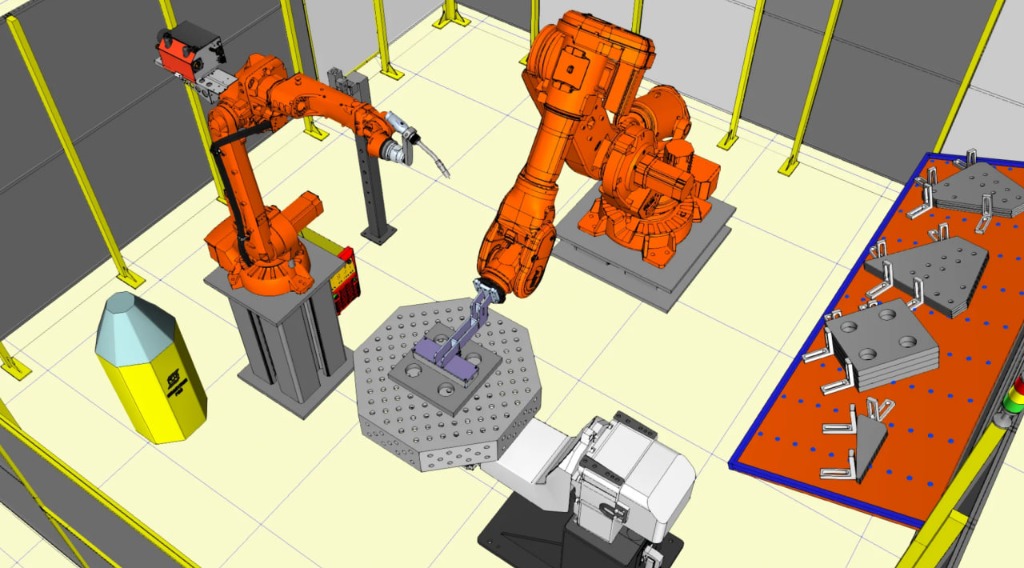
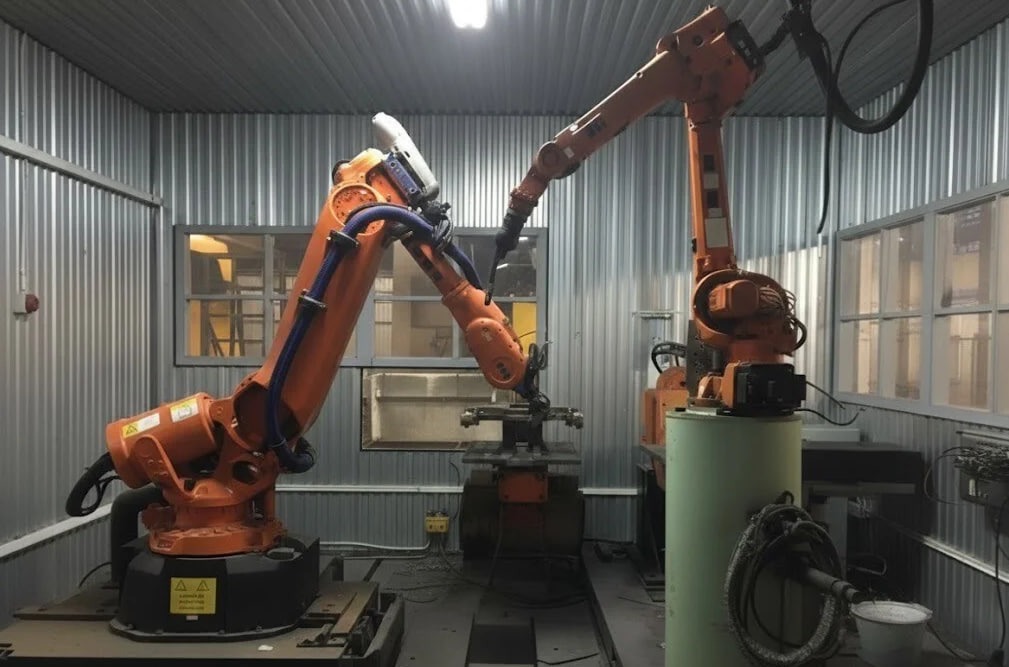
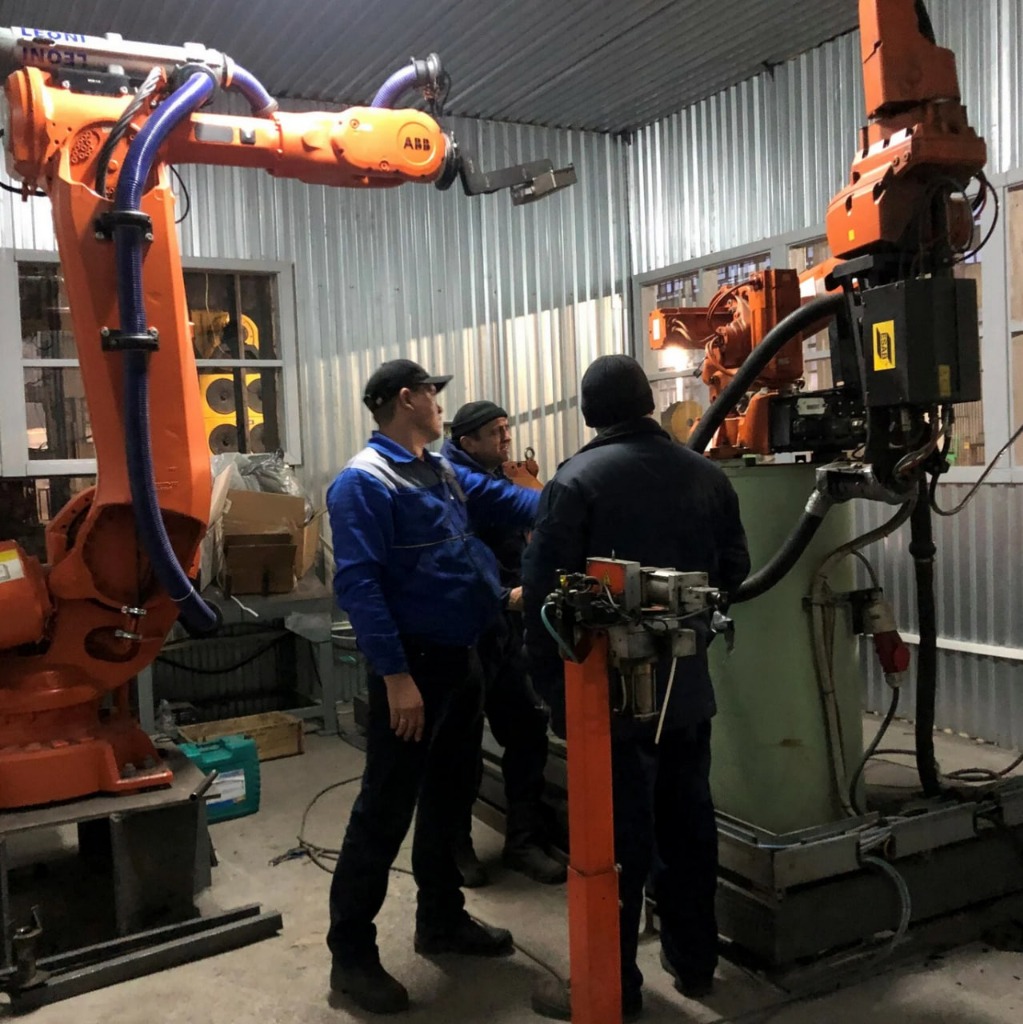
The installed cell is designed for serial production using touch-up programming. The system features a synchronized dual-robot configuration integrated with a heavy-duty 2-axis positioner.
Assembly Robot
Automates precise pick-and-place handling.
Welding Robot
Executes the taught welding program for repeated products.
2-Axis Positioner
Positions the workpiece within the coordinated cell.
Master Control
Unified program for synchronized kinematics.
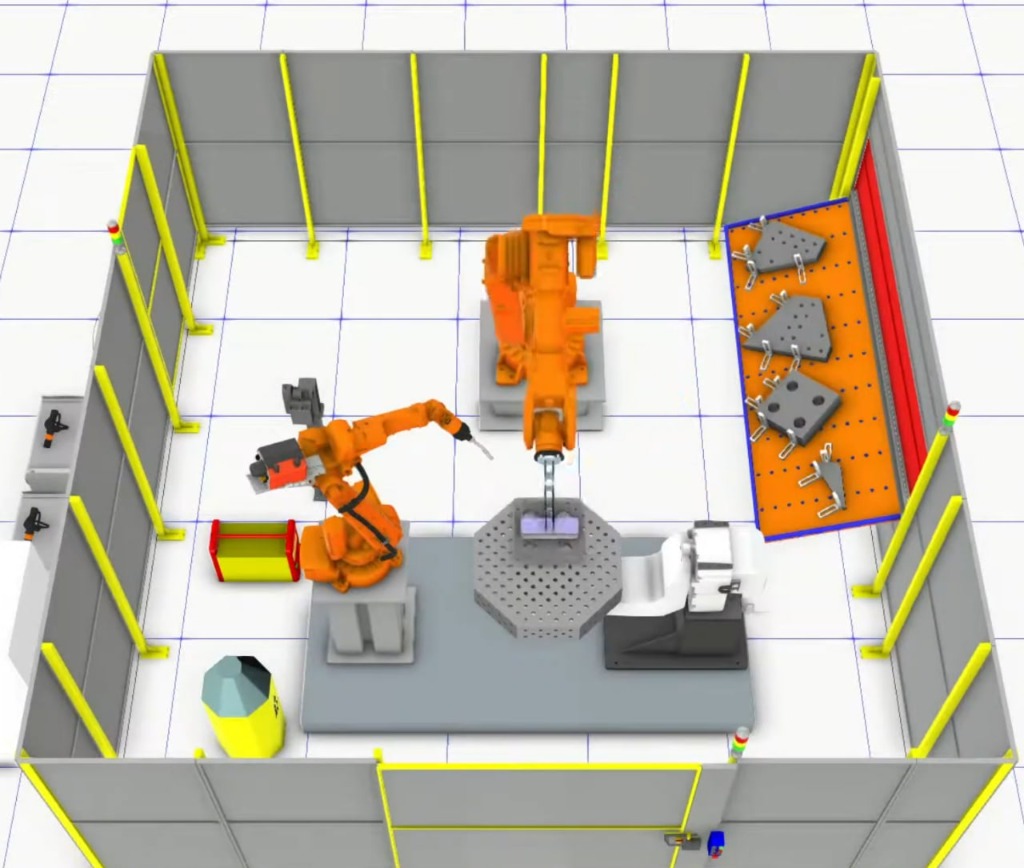
Cell Configuration
Coordinated robots for foundation support assembly and welding
Automated parameters improve consistency and reduce operator variation
Taught points for repeated products; not Tekla-generated beam jobs